← All research topics
UAV-based Precision Agriculture
From drone images to weed maps and sprayer-ready management zones.
Background
Variable-rate weeding machines (row cultivators, ground sprayers, spraying drones) need to know where weeds are and how dense they are. Before crop emergence every green plant is a weed, but once crops and weeds grow together, a weed pressure map is hard to make. Flying higher saves storage and flight time, yet individual plants are no longer visible.
Objectives
- Estimate weed pressure from UAV images taken at 20–30 m, where single plants cannot be told apart.
- Detect Cirsium arvense patches and convert detections into zones a real sprayer can use.
- Keep computing and training-data needs low enough for practical use.
Methodology
- A six-phase feature-based method: plant coordinates and sizes, crop row direction and spacing, clustering and line fitting, gap filling, removal of in-row plants to isolate weeds, and heat map and shapefile output. It needs no training data.
- A single-class YOLO detector trained on 800 annotated tiles (augmented to 13,280 images, 92,544 weed instances) on imagery from 12 m and 25 m, with a marker-based geometric transformation into geographic coordinates.
Results
- Tested on 208 images and 120 artificial datasets; with 678 crop plants and 600 weeds the plant classification reached F1 = 86.32 % at 4 % row disturbance, and the weed-to-crop ratio correlated 98–99 % with ground truth.
- The in-row concentration ratio (IRCR) flags heavily infested images whose results should be discarded and also indicates weed pressure.
- YOLO detection: [email protected] = 78.97 %, F1 = 77.2 %. Spot spraying treated 32.43 % of the field, a 67.57 % herbicide reduction versus full-area spraying.
Related publications
2026conference proceedings, not refereed
UAV-Based Detection and Precision Management of Cirsium arvense: An End-to-End Workflow from Deep Learning to Variable-Rate Spraying
L. Moldvai, P. Á. Mesterházi, G. Teschner, A. Nyéki
Proceedings of the 17th International Conference on Precision Agriculture (ICPA) and 11th Brazilian Congress on Precision and Digital Agriculture, Porto Alegre, Brazil, 13–15 July 2026
Abstract
An end-to-end workflow for detecting creeping thistle (Cirsium arvense) in UAV imagery and turning the detections into sprayer-compatible management zones. A single-class YOLO model trained on 800 annotated tiles (augmented to 13,280 images) reached [email protected] = 78.97 % and F1 = 77.2 %. Herbicide was needed on only 32.43 % of the field, a 67.57 % reduction compared with full-area spraying.
2025Q1
Aerial Image-Based Crop Row Detection and Weed Pressure Mapping Method
L. Moldvai, P. Á. Mesterházi, G. Teschner, A. Nyéki
Agronomy 2025, 15(8), 1762
Abstract
A six-phase, feature-based computer vision method that detects crop rows and generates weed pressure maps from UAV images taken at 20–30 m, without training data or deep learning. Tested on 208 images and 120 artificial datasets; the in-row concentration ratio (IRCR) tells whether a result is usable. With 678 crop plants and 600 weeds the method reached F1 = 86.32 %, and the weed-to-crop ratio correlated 98–99 % with ground truth.
DOI: 10.3390/agronomy15081762
Conferences
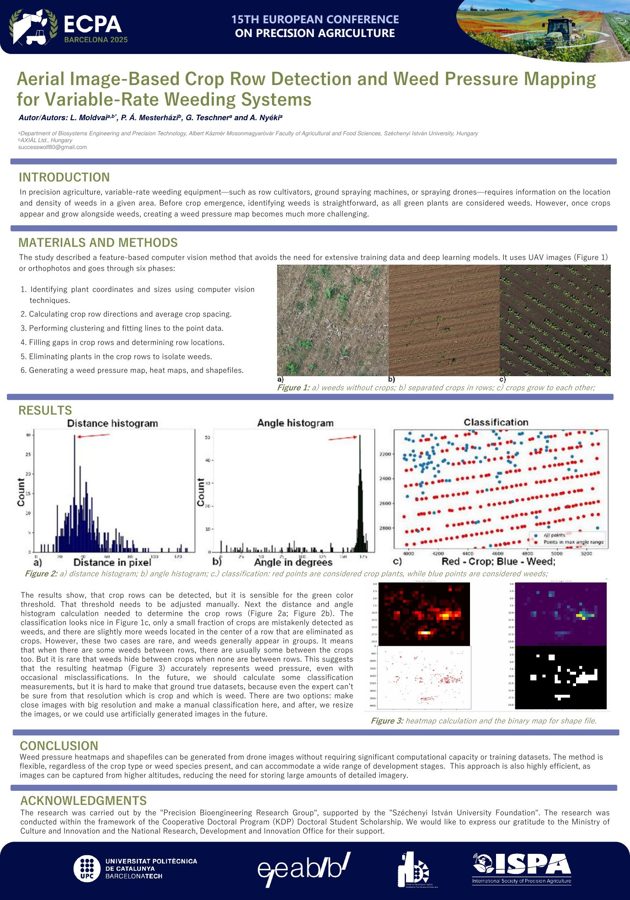
Poster29 June – 3 July 2025
Aerial Image-Based Crop Row Detection and Weed Pressure Mapping for Variable-Rate Weeding Systems
15th European Conference on Precision Agriculture (ECPA 2025), Barcelona, Spain
Feature-based method that creates weed pressure heat maps and shapefiles from drone images, with no training data and low computing needs. Poster no. 81 in the Book of Posters.
Poster (PDF)Book of postersRelated article